Vision Is Representation Under Pressure
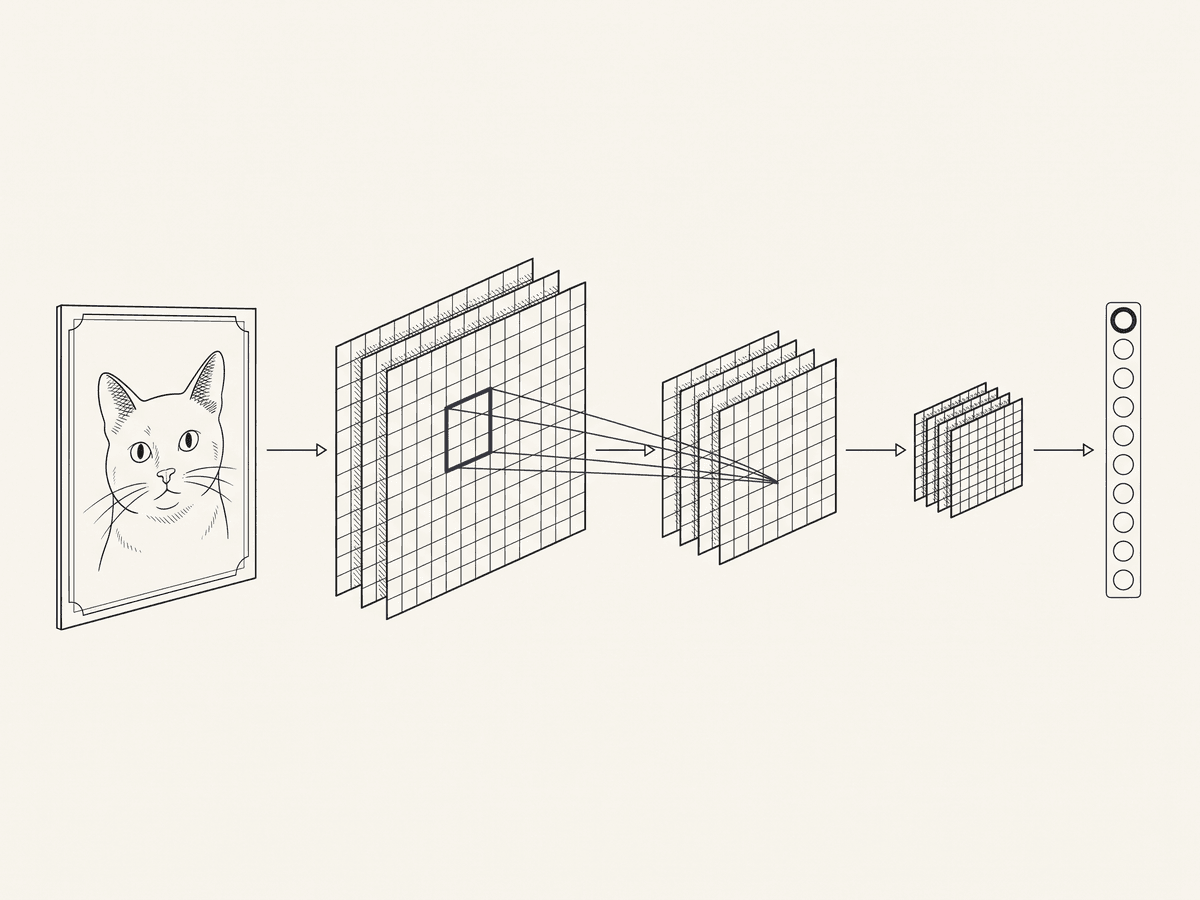
From pixels to systems, under pose, lighting, scale, and occlusion.
Pixels to representations, and what breaks them
From pixels to systems, under pose, lighting, scale, and occlusion.
The split as the only instrument on generalization, and its two leaks.
One matrix, one averaged template per class, and the limit that follows.
Reading the loss curve as an instrument before accuracy can speak.
The chain rule as bookkeeping, and the three bugs that break it.
Hidden layers as learned coordinates, defended only by an easier comparison.
Five setup choices that make good architectures look broken when they disagree.
The inspection loop: overfit ten examples before the model earns a dataset.
A two-dimensional spiral where every failure arrives as a visible shape.
Locality and repetition written into the wiring, and what the prior costs.
Probes that catch a model using wrong evidence while you can still act.
Two numbers, dataset size and distance, that set the whole transfer plan.
One compressed state carried forward, as mechanism and as ceiling.
Queries, keys, and values as retrieval, one context per generated word.
Routing promoted to the backbone, and the recipe that pays for it.
Three families, each buying one property and paying in a fixed direction.
A scene stored as a queryable function, supervised by photographs alone.
Training gradients turned against the model, and defenses that need named attackers.
The old habits that survive every architecture because the failures survive too.
Exact likelihood, paid for in pixel order and sampling speed.
Six jobs, six contracts, and the family choice that follows the metric.